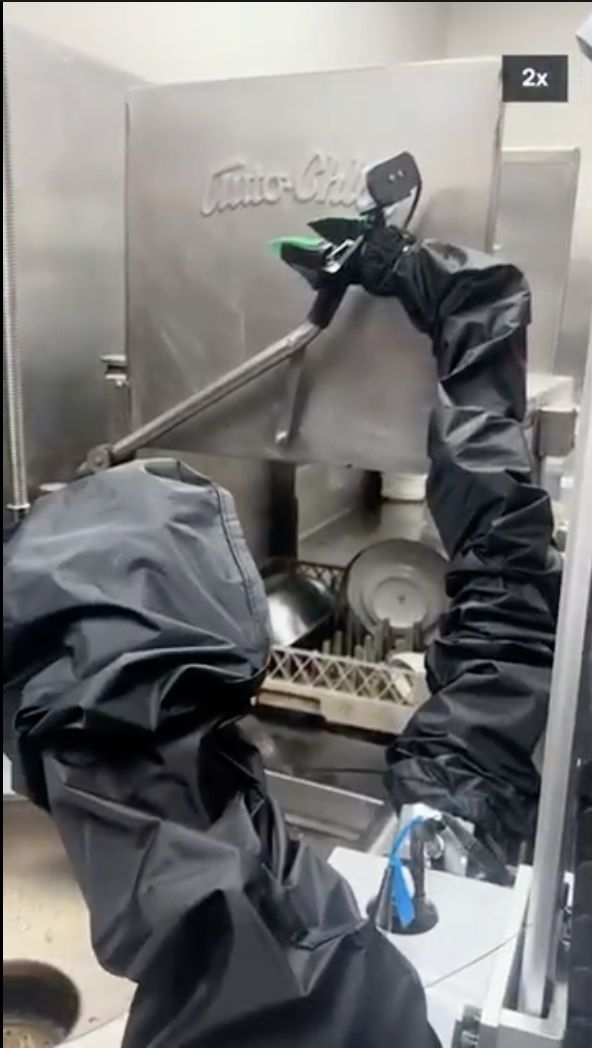
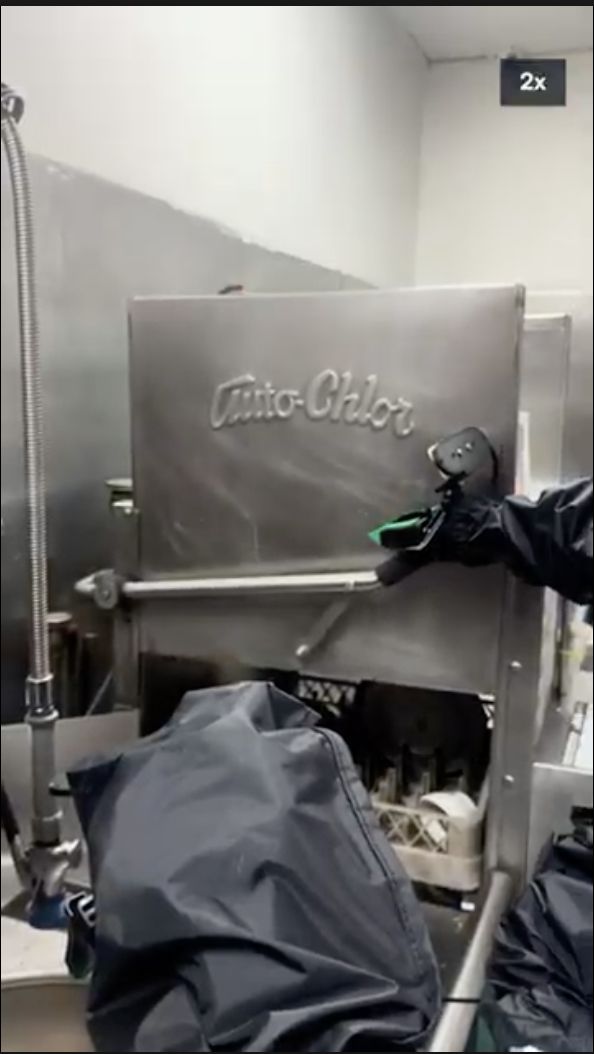
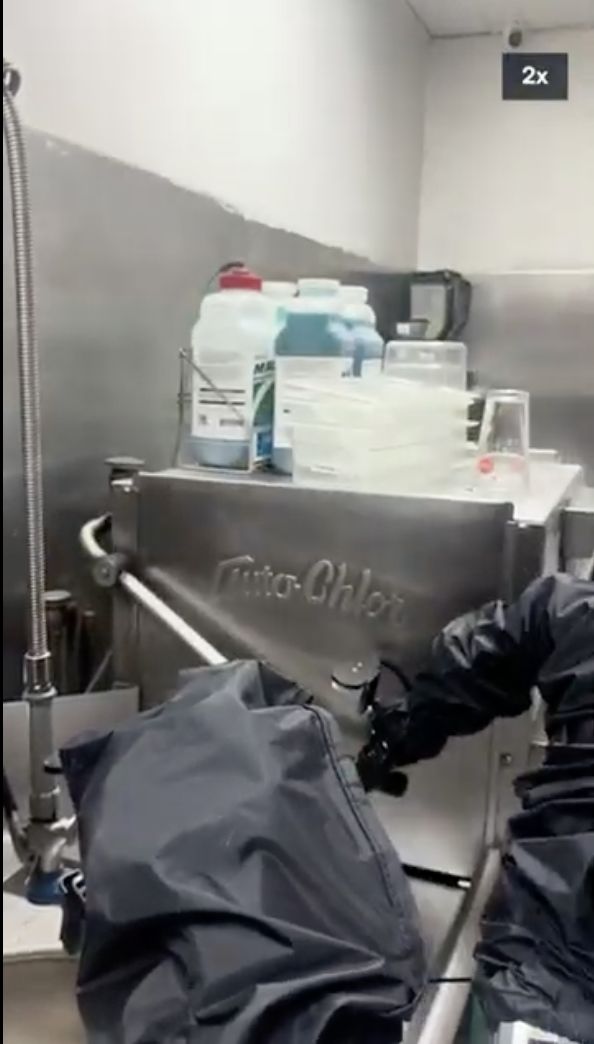
Recursive self-improvement for physical AI
Everything that has been digitised has been learned. Text, code, images, speech: anything that fits on a screen now has a model that gets better at it every few months.
But the digital world is a thin film over the physical one, and by our estimate it captures less than 0.001% of it. Under the film are the atoms. Every object that has to be lifted, turned, opened, stacked or carried is still moved by a hand.
If you can build something that improves itself in the physical world, you unlock realities humans can't yet imagine. It starts with a world where you don't have to lift a finger to move anything, and it ends with every atom around you being manipulated at will.
Every leap forward has come from learning beyond the limits of reality
-
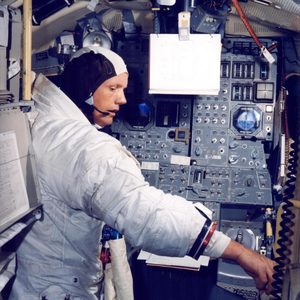
1969The limitApollo landing procedures had to account for uncertain computer alarms. One wrong abort call could end the mission.The world built to learn inSimulated lunar landings that rehearsed alarms and abort decisionsWhat it unlockedApollo 11 flew through the real 1201 and 1202 alarms and landed on the Moon
-
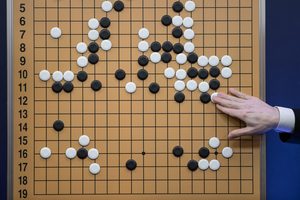
2017The limitGo AI learned from expert human games. Human knowledge capped where discovery could start.The world built to learn inAlphaGo Zero played millions of games against itselfWhat it unlockedSuperhuman play with no human game data
-
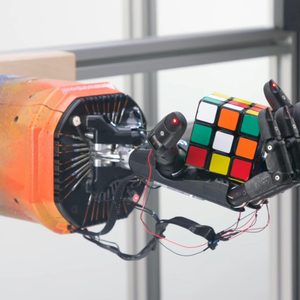
2019The limitRobot dexterity depended on real-world experiments. Physical data was slow and expensive.The world built to learn inA robotic hand trained in simulations that grew more randomized as it improvedWhat it unlockedA real robot hand solved a Rubik's Cube
-
2026you are hereThe limitRobots learn from demonstrations in the physical world. Expensive, slow and dangerous.The world built to learn inInfinite worlds for robots to learn inWhat it unlocks???
-
Next
A world where nobody has to lift a finger to move anything.
-
Then
Every atom around you, manipulated at will.